Charlotte Morissette
PhD Student in AI and Robotics | University of Toronto - Vector Institute
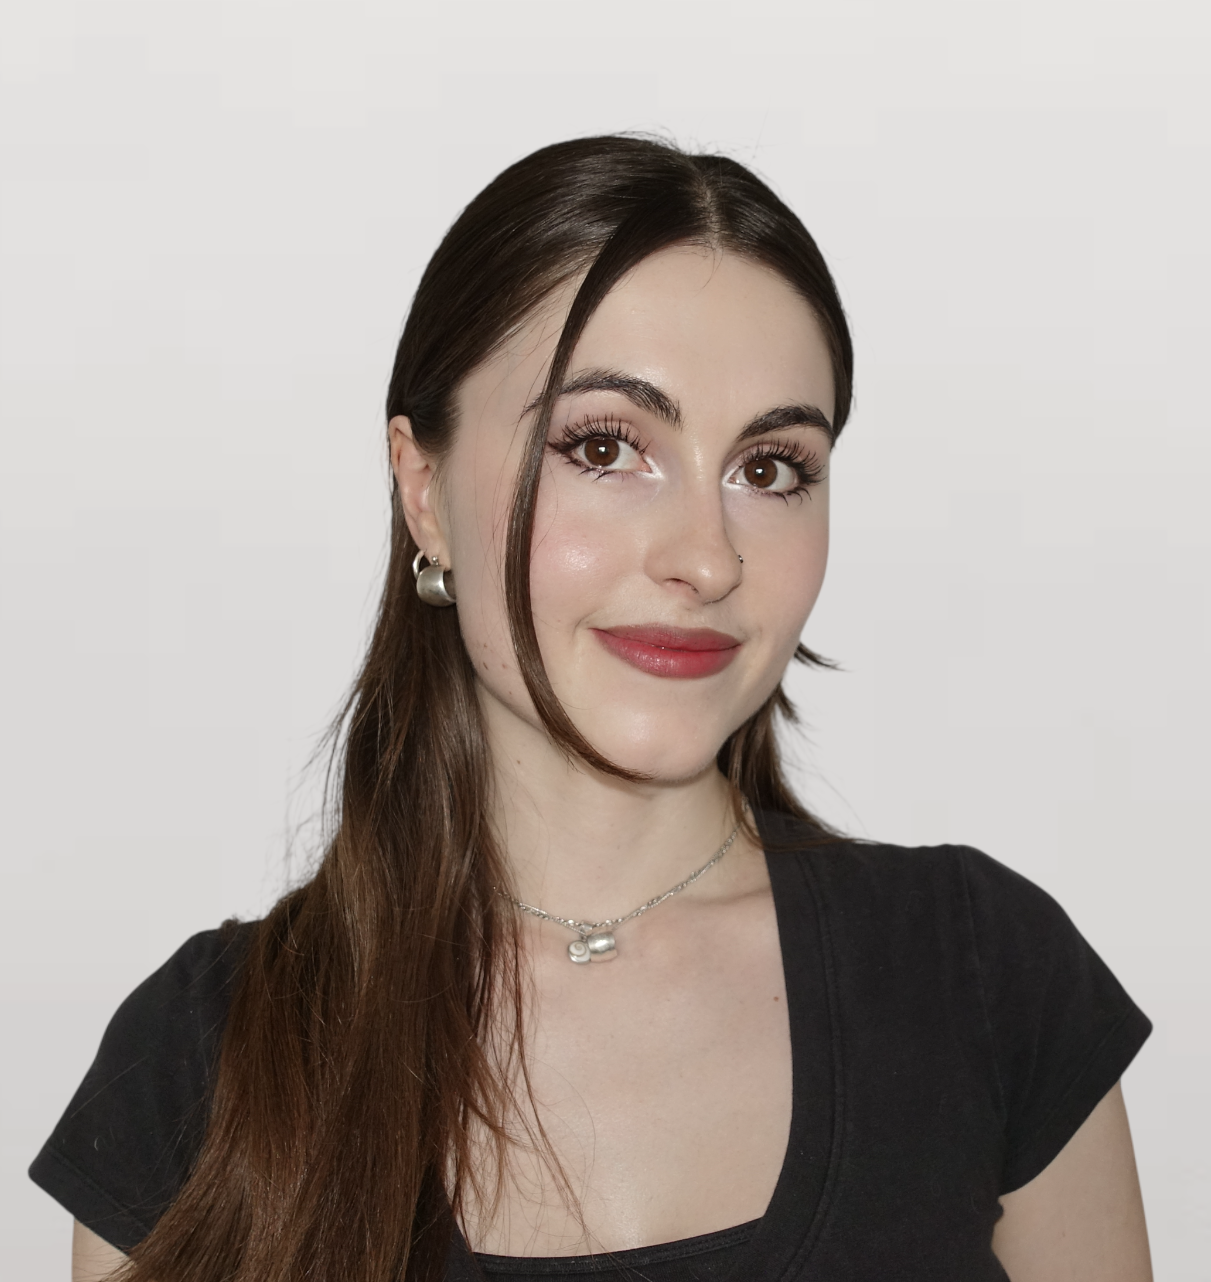
I am a PhD student in Robotics at the University of Toronto - Vector Institute, advised by Professor Jonathan Kelly following a master’s at McGill University under Professor Gregory Dudek. My research is primarily in robot learning, more specifically in modality fusion, tactile sensing, foundation models, reinforcement learning, HRI, and computer vision. More recently, my work has focused on efficient modality fusion in VLA models for robotic manipulation, with a particular emphasis on tactile sensing.
If our interests align, please feel free to reach out — I am always happy to discuss potential research or collaboration opportunities.
Select Publications
-
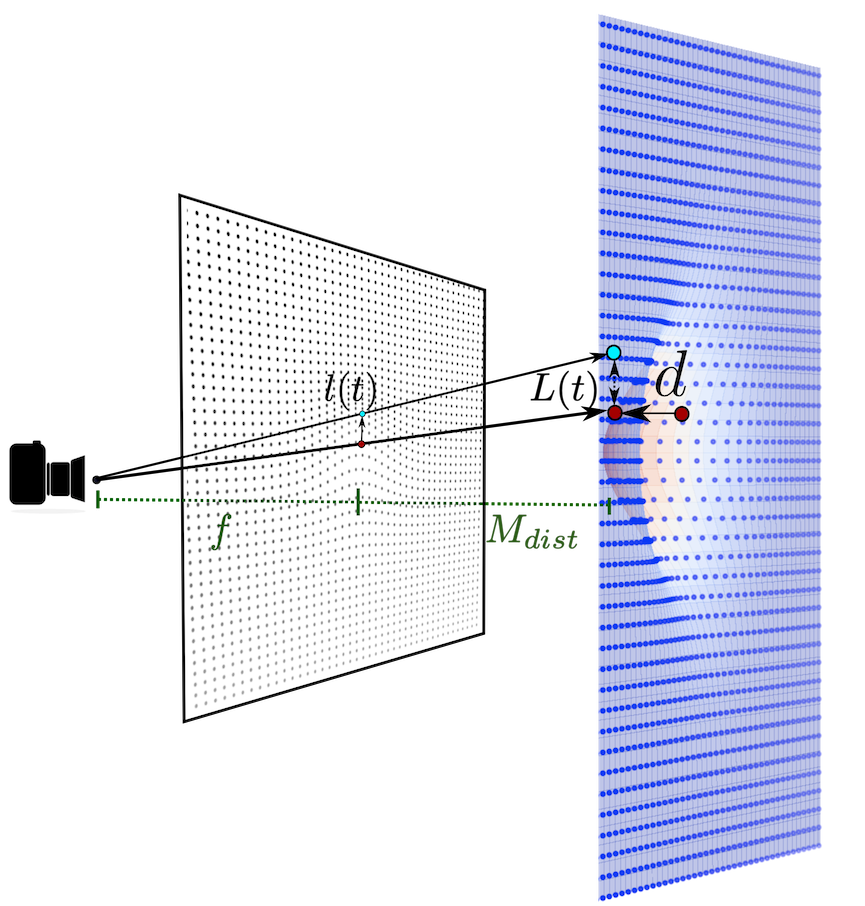 Visual-Tactile Inference of 2.5 D Object Shape From Marker TextureIEEE Robotics and Automation Letters (RA-L), 2024
-
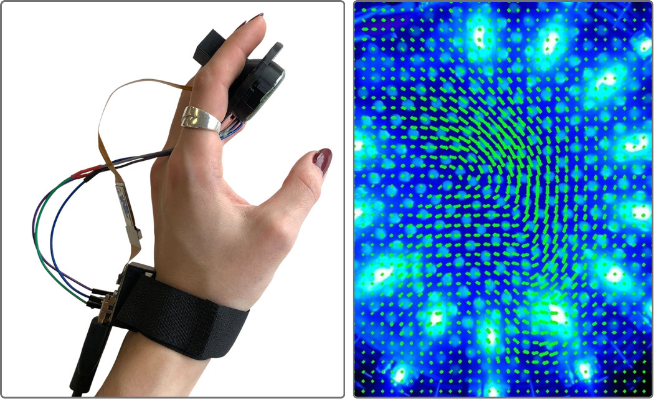 A Study of Human-Robot Handover through Human-Human Object TransferNeural Information Processing Systems (NeurIPS), Human in the Loop Learning (HiLL) Workshop, 2022